


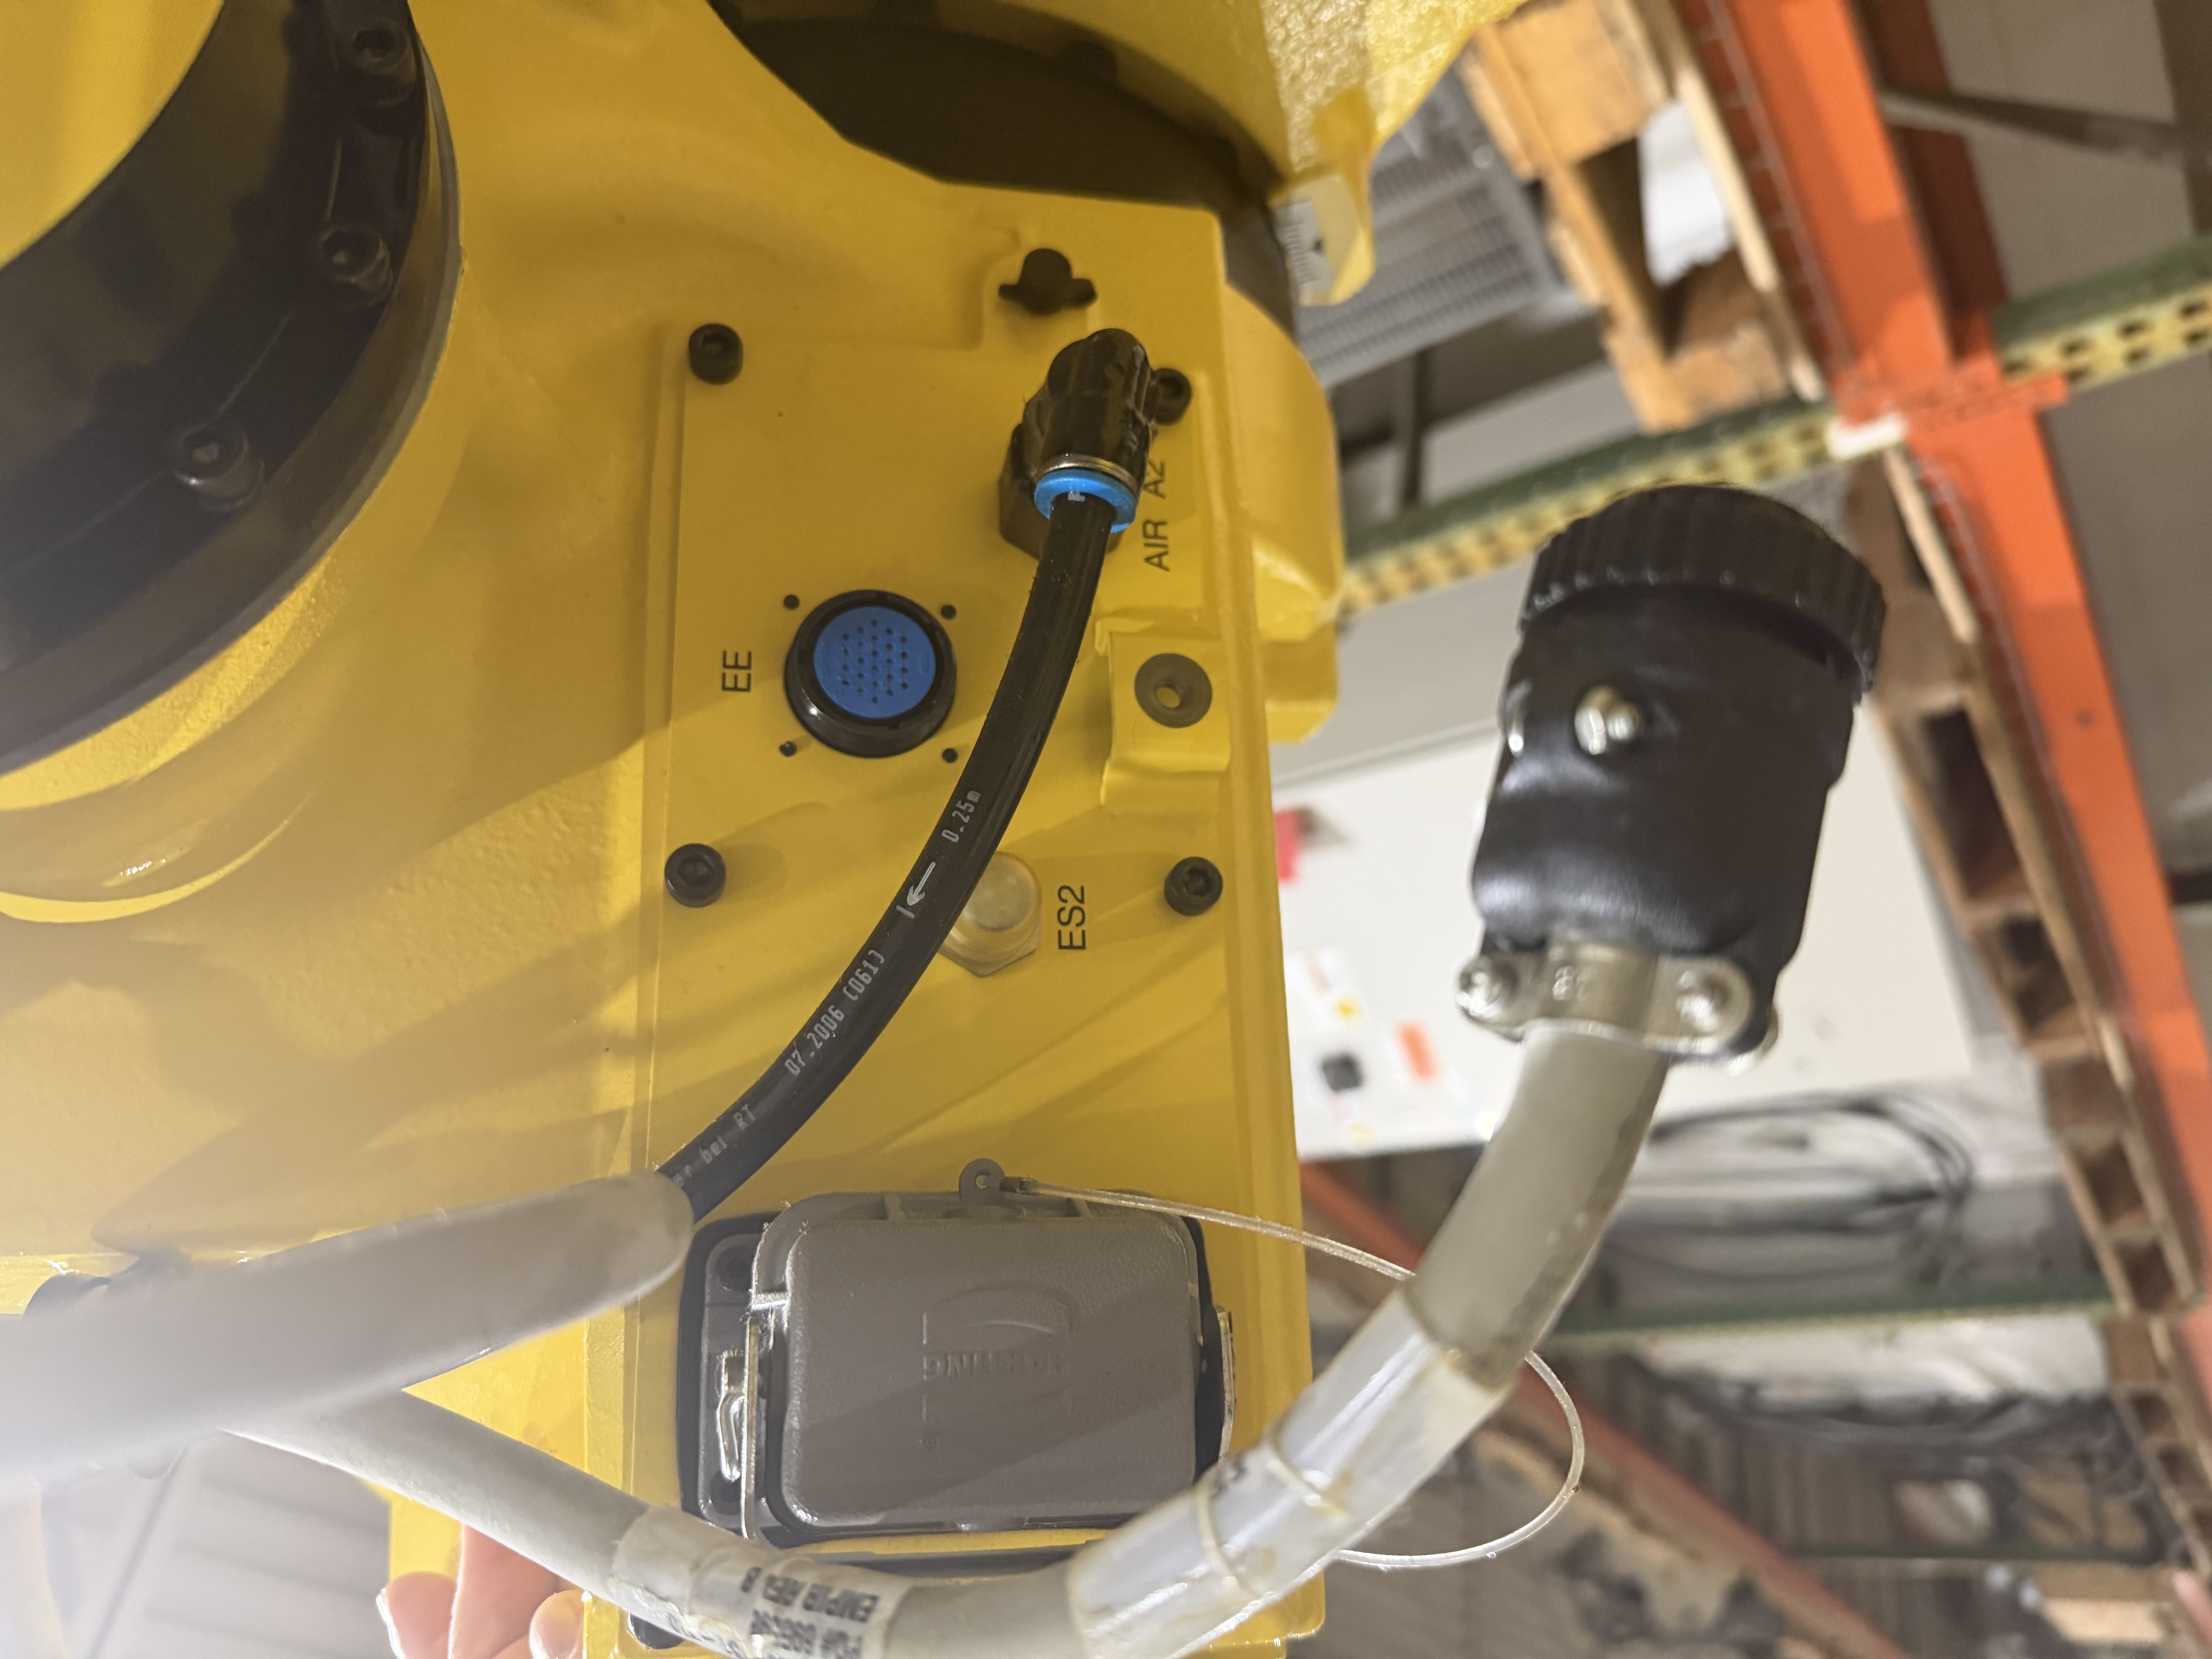
The EE (End Effector) connection on a Fanuc robot is a multi-pin electrical connector (commonly 12-pin or 24-pin, depending on the model) located on the robot arm—typically near the wrist, J3, or J4 axis.It is used to interface the robot controller with end-of-arm tooling (EOAT), such as grippers, sensors, solenoid valves, or other devices mounted on the tool flange. It supplies:Digital outputs (RO / Robot Outputs) to control actuators (e.g., open/close a pneumatic gripper via valves)
- Digital inputs (RI / Robot Inputs) to read feedback signals (e.g., part present, gripper status, or other sensors)
- 24 V DC power and ground for the tooling
This allows direct, dedicated I/O communication between the robot and its tool without always needing external junction boxes or a full PLC for basic functions. Pinouts and exact capabilities vary by robot model and controller (e.g., R-30iA/B), so always refer to the specific mechanical unit or maintenance manual for wiring details.
You can call RAB Industries for further assistance at (586)752-0090